
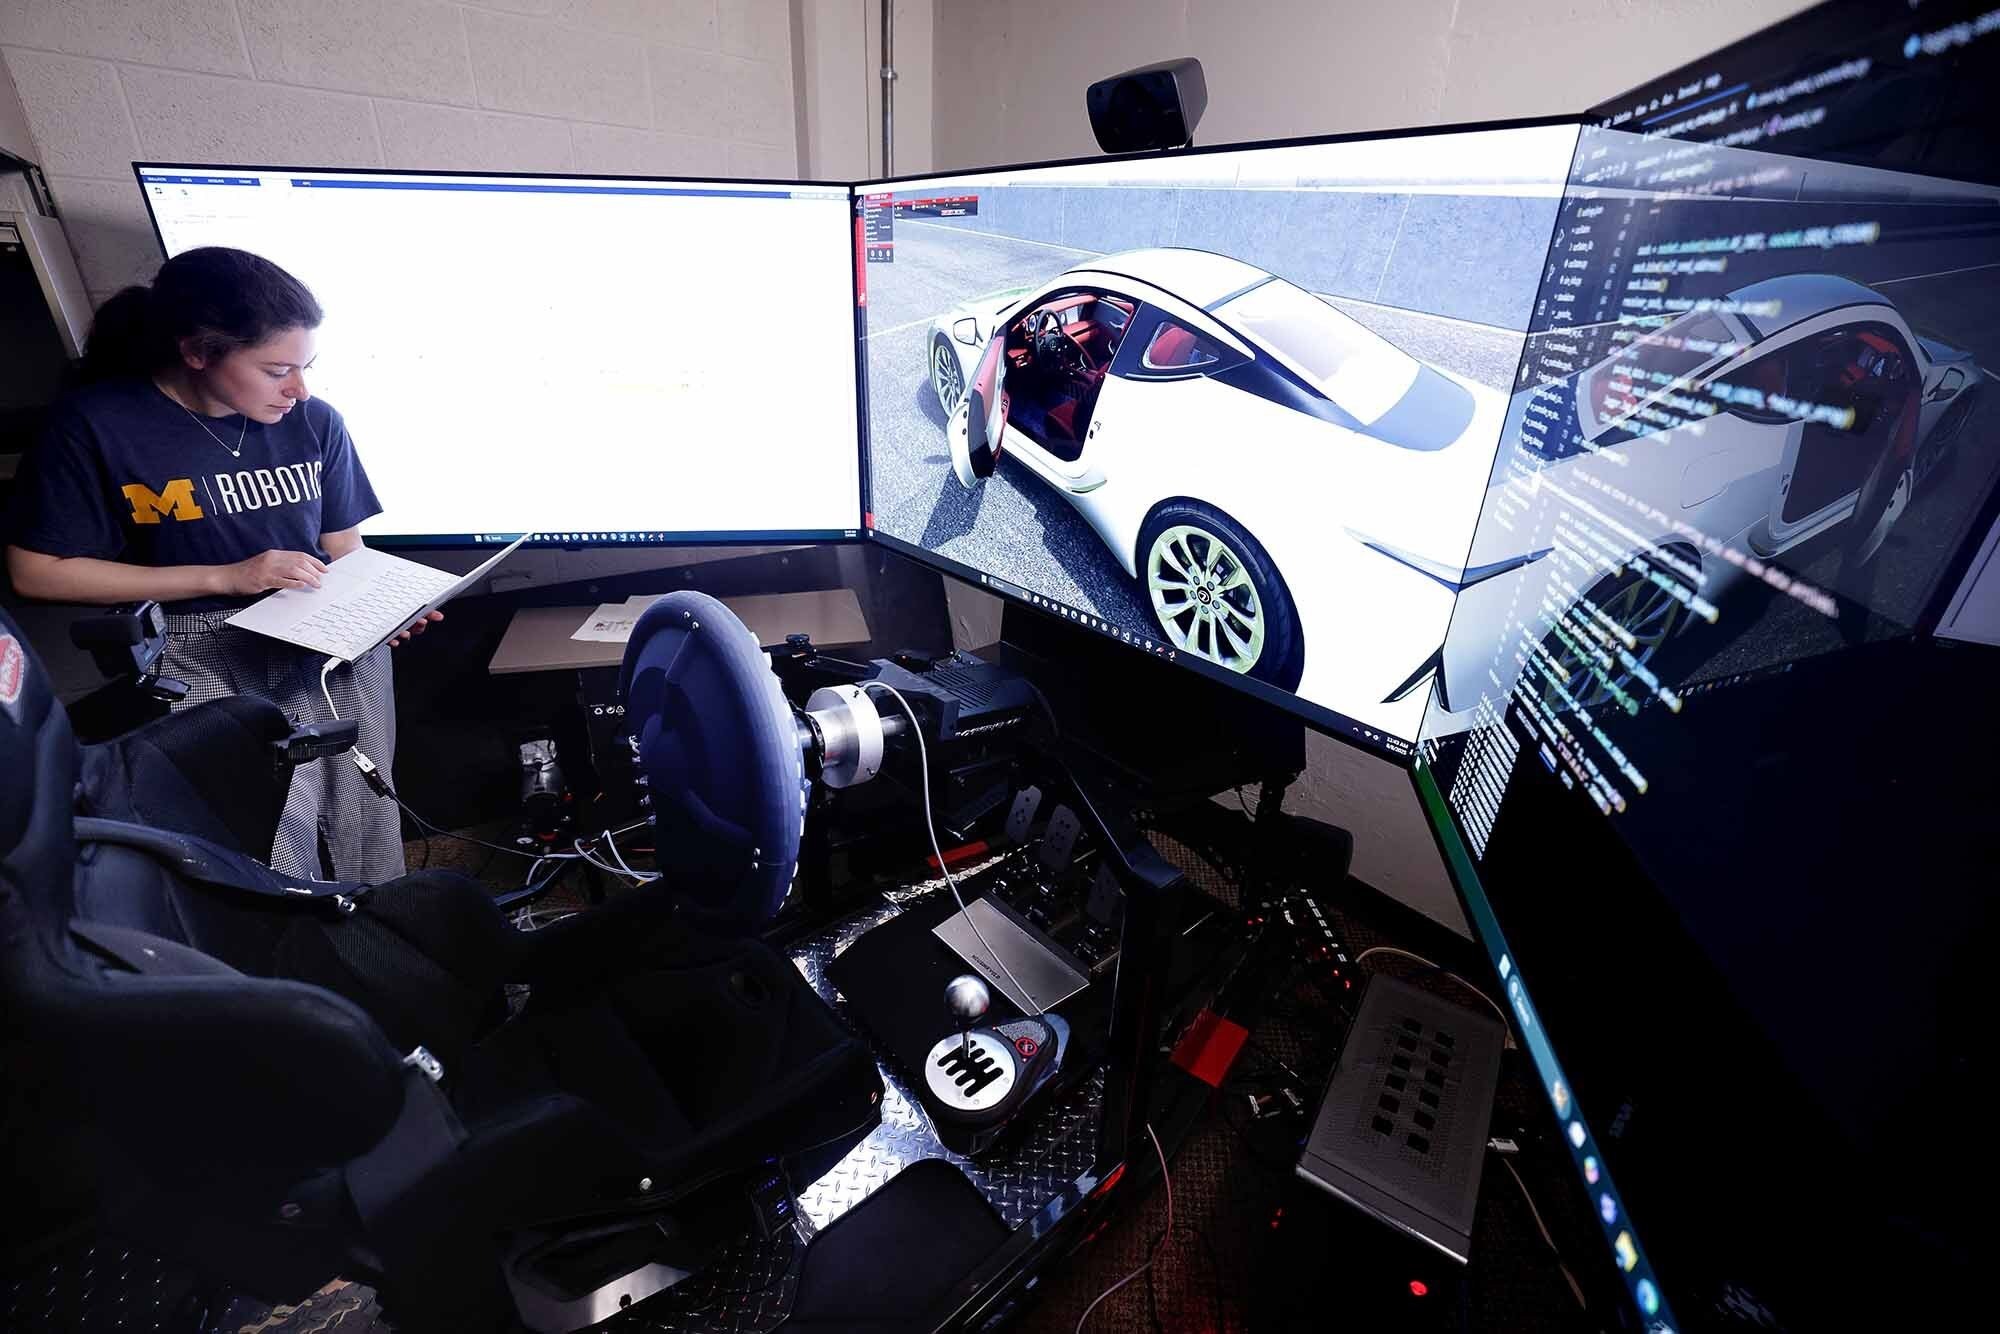
The University of Michigan pneumatic haptic steering wheel prototype embeds inflatable air sacs beneath the leather hand grips to negotiate steering force between human drivers and driver-assist software. While currently an experimental hardware platform funded by the Toyota Research Institute, production implementations of equivalent Level 2+ driver-assist hardware suites sell for $2,500 USD direct through Mercedes-Benz dealerships via the MB.Drive Assist Pro package. This specific hardware mod targets highway commuters who navigate semi-autonomous hand-offs and frequently fight electronic power steering motors during unexpected maneuvers.
🛒 Where to Buy: Toyota Research Institute Pneumatic
Editorial Note & Product Verification: The Cool Great Buys editorial desk independently verifies manufacturer technical specifications, cross-checks active retail availability across authorized sellers, and evaluates verified consumer reliability data before publishing product evaluations. All featured prices and promotions reflect active market rates at the time of publication.
- Toyota Research Institute Pneumatic: View on Amazon
Click the link above to check current pricing, availability, and customer reviews on Amazon.
Shared control between human drivers and driver-assist algorithms creates dangerous physical ambiguity. When a semi-autonomous system detects a hazard, it applies corrective steering torque. If a human driver panics or disagrees, they muscle the wheel in the opposite direction. This physical battle can break the system engagement or cause sudden vehicle swerving. In worst-case scenarios, ambiguous vehicle control can have tragic consequences. Existing driver-assist systems rely on harsh audio beeps or visual dashboard alerts. These warning methods fail to tell the driver what the steering system actually wants to do before the vehicle moves. Initial product disclosures and reporting were tracked via Thedrive.
The transition toward fully autonomous driving remains hindered by the infamous “hand-off problem.” When software algorithms encounter scenarios beyond their operational design domain—such as faded lane markings, heavy snow accumulation, or complex construction zones—control must be transferred back to the human driver immediately. Traditional visual and auditory warnings often result in a delayed response time averaging 2.5 to 8 seconds. During this critical window, a vehicle traveling at 70 miles per hour covers hundreds of feet without attentive supervision. By replacing passive alarms with active, mechanical tactile prompts directly under the driver’s palms, the pneumatic haptic interface aims to bridge this cognitive gap through subconscious physical feedback rather than startling high-decibel tones.
Pneumatic Architecture and Micro-Fluidic Hardware Design
At the mechanical core of this prototype lies a network of micro-pneumatic actuators integrated beneath a 1.2-millimeter layer of perforated semi-aniline leather. Unlike standard steering wheels that rely on simple eccentric rotating mass vibration motors or piezoceramic buzzers, this hardware utilizes localized expansion bladders. The internal assembly comprises eight independently controlled elastomeric air sacs positioned strategically at the 9 o’clock and 3 o’clock grip positions, alongside secondary chambers located along the upper quarter-rim and thumb rests. These micro-sacs are plumbed directly to a compact 12-volt air compressor manifold hidden within the central steering hub hub-armature, measuring under 85 millimeters in total width.
Airflow management is governed by high-speed solenoid micro-valves capable of modulating internal bladder pressure between 2.0 and 18.5 PSI (13.8 to 127.5 kPa) with a rapid activation latency under 18 milliseconds. The pneumatic controller operates in tandem with high-density capacitive sensor arrays beneath the leather surface and dual strain-gauge torque sensors mounted directly to the steering column shaft, capable of measuring rotational force with a precision of 0.05 Newton-meters. This sensor arrangement allows the central unit to dynamically compute the exact contact area, grip force, and hand placement of the driver in real time, delivering localized pressure pulses precisely where the operator’s hands make contact.
By adjusting the inflation velocity, pressure amplitude, and duty cycle of each individual chamber, the pneumatic wheel generates distinct physical sensations. The hardware can simulate a gentle swelling motion, a localized tap, a continuous dynamic wave across the palm, or a firm directional nudge that physically shifts the driver’s hand positioning. Power consumption for the entire pneumatic pump and solenoid manifold averages roughly 12 watts during active modulation phases and drops to negligible quiescent levels when idling, making it exceptionally lightweight in its electrical draw compared to high-torque electric power steering servo motors that routinely pull hundreds of watts during force-feedback maneuvers.
Tactile Ergonomics and In-Cabin Human-Machine Interface Testing
In real-world evaluation scenarios, the primary physical sensation delivered by the pneumatic rim is strikingly different from traditional haptic feedback. Traditional vibration motors trigger rapid adaptation in the skin’s Pacinian corpuscles, leading to sensory numbness and driver annoyance after prolonged exposure. In contrast, the inflatable air sacs engage the skin’s slowly adapting type I (SA-I) Merkel discs and type II (SA-II) Ruffini endings through continuous, low-frequency displacement. The resulting sensation mimics a gentle, rhythmic breathing motion against the driver’s palms, creating an organic physical connection rather than an aggressive electrical buzzing.
During active highway testing, this organic sensation proves immensely valuable for subtle spatial orientation. When the vehicle’s semi-autonomous software detects a subtle drift toward a left-hand lane boundary, the micro-valves inflate the outer left air sacs while slightly deflating the inner right chambers. This pressure delta creates a natural, intuitive rolling force against the driver’s left palm, prompting them to micro-adjust steering alignment without taking their eyes off the road. The driver receives spatial intent before any mechanical torque is applied to the front rack, eliminating the alarming “tug-of-war” feeling typical of aggressive lane-keep assist systems.
The system also excels during emergency override maneuvers. If an unexpected obstacle appears and the driver instinctively swerves against the vehicle’s automated trajectory, capacitive sensors detect the rapid increase in hand pressure within 10 milliseconds. The pneumatic manifold responds by dumping bladder pressure through quick-exhaust exhaust ports, softening the physical resistance of the rim instantly. This immediate pneumatic pressure drop serves as a soft mechanical clutch, signalling to the driver that control has been fully surrendered without triggering abrupt mechanical snapback or destabilizing the vehicle’s chassis dynamics.
Nighttime driving evaluations reveal additional safety benefits by drastically reducing visual distraction inside the cabin. Standard advanced driver-assistance systems rely on flashing instrument cluster iconography or head-up display graphics to communicate software confidence and impending system hand-offs. These visual alerts force the driver’s eyes to refocus from far-distance roadway conditions to near-distance cabin screens, increasing cognitive load. The pneumatic wheel completely decouples system status communication from the visual domain, transferring operational state awareness entirely to the driver’s somatosensory system.
Competitive Benchmarking: Pneumatic Sacs vs. Industry Alternatives
To evaluate the market viability of Toyota’s pneumatic concept, it must be benchmarked against existing commercial driver-assist monitoring and feedback technologies currently available in high-end production vehicles. Today’s automotive industry relies primarily on three competing interface methods: rotational torque-nag monitoring, capacitive-only touch surfaces, and high-frequency vibrotactile actuators embedded within the steering rim core.
Tesla’s Autopilot and Full Self-Driving hardware suites historically relied on rotational column torque monitoring. To confirm driver engagement, the system requires the operator to apply a continuous, slight twisting force (typically 0.8 to 1.2 Newton-meters) against the steering column. This crude approach frequently results in “steering wheel nags,” forcing drivers to intentionally apply unwanted torque, which can accidentally disengage the system or cause sudden vehicle deviation. In direct comparison, the pneumatic wheel eliminates torque-nag requirement entirely, using capacitive surface grids for presence detection and soft air expansion for directional intent, eliminating false disengagements completely.
General Motors takes a visual-centric approach with its Super Cruise hardware environment, which combines an infrared eye-tracking camera mounted on the steering column with a prominent LED light bar integrated across the top portion of the wheel rim. While highly effective at tracking driver gaze, the system provides zero tactile force feedback regarding vehicle intent. If the driver is looking forward but misjudges a curve, the light bar simply transitions from green to flashing red, relying on the driver to process the visual warning and physically compute the required steering input. The pneumatic architecture outperforms this approach by physically guiding the driver’s hands in the exact direction of required correction before the visual hazard escalates.
Mercedes-Benz offers the $2,500 MB.Drive Assist Pro option, which utilizes dual-zone capacitive wrap sensing and localized vibration pulses within the leather grip. While superior to basic torque-nag systems, high-frequency vibrotactile buzzers fail to communicate directional vectors; a vibration on the left side feels structurally identical to a vibration on the right side, conveying urgency but not directional trajectory. The Toyota Research Institute pneumatic prototype addresses this limitation directly by creating localized pressure gradients across three dimensions, physically pushing or yielding against specific fingers to communicate continuous vector geometry rather than a simple binary alert.
Manufacturing Engineering, Thermal Resilience, and Production Economics
Translating an experimental academic prototype into an automotive-grade production component requires meeting rigorous OEM reliability, thermal, and mechanical durability standards. Steering wheels are subject to extreme operational environments, ranging from direct solar baking on a parked dashboard reaching internal cabin temperatures above +85°C (185°F) to sub-zero arctic cold soak conditions down to -40°C (-40°F). Elastomeric materials used in early pneumatic prototypes tend to suffer from material stiffening in cold climates and accelerated thermal degradation, air permeability, and micro-cracking under intense ambient heat.
To resolve these environmental degradation issues, production-ready iterations replace soft silicone bladders with multi-layer thermoplastic polyurethane (TPU) air sacs reinforced with aromatic polyester fabric scrims. These advanced polymers maintain elastic compliance across the entire automotive temperature spectrum while exhibiting near-zero air permeability over a 15-year design lifespan. The outer leather covering must also feature tailored micro-perforations and elastic stitching seams, allowing up to 6.5 millimeters of localized radial expansion without stretching out, wrinkling, or cracking the underlying material grain after thousands of inflation cycles.
Integrating pneumatic plumbing through the vehicle’s steering column introduces significant mechanical complexity. Standard steering wheels transfer power and data signals across a rotating clock spring—a ribbon cable wound inside a cylindrical cassette that turns with the wheel. Running flexible pneumatic lines through a conventional clock spring introduces severe bending fatigue and potential air leaks. Engineers solved this by housing the entire micro-compressor, solenoid valve manifold, and pressure reservoir directly inside the central hub of the steering wheel itself. As a result, the wheel requires only standard 12-volt DC power and high-speed CAN-FD data lines through the existing electrical clock spring, completely eliminating external air hoses running through the steering column assembly.
Noise, Vibration, and Harshness (NVH) testing presents another critical engineering hurdle. Micro-pneumatic pumps typically produce high-pitched motor whine and mechanical valve clicking that can disrupt the quiet ambient cabin environment of luxury electric vehicles. Acoustic dampening enclosures, rubber-isolated compressor mounts, and localized expansion mufflers are integrated directly around the central hub air manifold. These acoustic measures suppress operational pump noise below 28 dBA—well below the ambient cabin background noise floor during highway transit—ensuring that the pneumatic action is felt distinctly through the driver’s hands while remaining completely silent to passengers.
From a bill-of-materials (BOM) cost perspective, integrating micro-compressors, TPU air bladders, high-speed micro-valves, and capacitive arrays adds an estimated $350 to $500 in direct manufacturing costs over a standard heated, capacitive steering wheel. However, when packaged into premium Level 2+ and Level 3 driver-assist option groups—where consumer packages like Mercedes-Benz’s MB.Drive Assist Pro easily command $2,500—the incremental hardware cost is well within acceptable margins for luxury and mid-tier automotive platforms, particularly given the substantial reduction in hand-off risk and liability.
Detailed Hardware Specifications and System Architecture
To fully evaluate the mechanical engineering behind this haptic interface, it is helpful to analyze the explicit technical metrics, thermal limits, and physical dimensions governing the pneumatic assembly. The overall mass of the complete steering wheel unit, including the internal compressor hub, solenoid block, leather wrap, and capacitive sensor layer, comes in at approximately 1,420 grams. This represents a minor mass increase of just 180 grams compared to a conventional heated executive luxury steering wheel, keeping total rotational inertia low enough to avoid impacting electronic power steering feel or airbag deployment velocity.
The pneumatic pump system operates on a nominal 12-volt DC automotive electrical bus, drawing a maximum peak current of 1.2 amperes during rapid initial bladder pressurization and dropping to a continuous 0.1 amperes during steady-state pressure maintenance. The response time from software signal generation to 90% target bladder pressure is measured at 18.5 milliseconds, while quick-dump deflation latency takes less than 12 milliseconds through the mechanical exhaust ports. Maximum stroke displacement for each individual air sac reaches 6.5 millimeters in height, generating up to 8.2 Newtons of continuous localized tactile force directly against the driver’s palm surface.
Environmental operating parameters are rated for -40°C to +85°C ambient temperatures, supported by an IP64 dust and splash protection rating for all internal pneumatic valves and processing modules embedded within the hub armature. The underlying capacitive touch network operates at a sampling frequency of 100 Hertz with a spatial touch accuracy of 2.0 millimeters, ensuring the controller accurately maps hand location across 360 degrees of the rim circumference. Total continuous operational durability is validated up to 150,000 full expansion and contraction cycles per individual sac without measurable air pressure loss or material deformation.
Final Verdict: Can Inflatable Air Sacs Fix Driver-Assist Hand-Offs?
The Toyota Research Institute and University of Michigan pneumatic haptic steering wheel concept represents a significant technological leap forward in human-machine interface design for modern vehicles. By shifting the primary communication channel from intrusive audio beeps and distracting dashboard lights to subtle, three-dimensional physical feedback, this pneumatic technology elegantly resolves the physical friction and confusion that currently plague Level 2+ driver-assist systems. The interface removes the physical “tug-of-war” between human drivers and software algorithms, transforming a potentially dangerous battle for control into a smooth, collaborative dialogue.
While packaging micro-pumps, manifolds, and inflatable bladders inside a steering wheel rim adds production complexity and manufacturing cost, the safety benefits far outweigh the engineering hurdles. As semi-autonomous driving capabilities continue to expand across mainstream passenger vehicles, hardware interfaces that intuitively bridge the gap between human intuition and machine intelligence will become essential safety features rather than luxury gimmicks. Toyota’s pneumatic air sac architecture proves that the future of driver assistance isn’t just about making cars drive better on their own—it is about making cars and humans drive better together.